
 +86-574-5680 8878


0102030405
Gyroscope vs Random Navigation: Coverage Heatmap Test
2026-08-11
TL;DR. A side-by-side coverage heatmap test on 3 pool geometries (rectangular, L-shaped, kidney-shaped) shows gyroscope navigation achieves 95-99% coverage while random navigation achieves 75-85% coverage — an average gap of 15 percentage points. Random navigation generates 18-30% redundant movement, while gyroscope navigation generates 2-5% redundant movement. The coverage gap is widest on L-shaped and kidney-shaped pools (18-22 percentage points) and narrowest on rectangular pools (10-13 percentage points). For buyers evaluating AquaJack 600 robotic cleaner or comparing smart navigation pool robots, the gyroscope design reduces wall-bounce mechanical stress, extends effective battery runtime, and lowers the return rate driven by visible cleaning gaps. The navigation engineering behind pool robots reference article explains the underlying sensor architecture. To request quotation, contact Poolstar export team.

The navigation algorithm inside a cordless robotic pool cleaner determines whether the pool floor gets uniformly cleaned or whether corners and steps get repeatedly skipped. Two navigation philosophies dominate the residential pool robot market in 2026: gyroscope-based systematic navigation, which uses an inertial measurement unit to track position and drive a deliberate back-and-forth path, and random navigation, which drives forward until hitting a wall, then turns at a random angle and drives again. Both philosophies claim to clean the pool. The coverage heatmap test below shows what actually happens on real pool geometries over a single cleaning cycle.
Why Navigation Algorithm Matters for Pool Robot Retailers
Navigation algorithm matters for pool robot retailers because the visible cleaning result drives the buyer return decision. A pool owner who runs the robot once and finds debris remaining in the corner returns the unit at a much higher rate than a pool owner who runs the robot once and finds the floor uniformly clean. The return rate differential between gyroscope-navigation and random-navigation units is typically 3-6 percentage points in the first 90 days, which over a 1,000-unit annual retail volume translates to 30-60 additional returns and $2,000-$5,000 in additional return processing cost per year.
Navigation algorithm also drives the warranty exposure on mechanical components. Random-navigation units that drive forward until hitting a wall experience a wall-bounce collision event 50-100 times per cleaning cycle, depending on pool size. The cumulative mechanical stress over 500 cleaning cycles (3-year battery life) drives fatigue in the wheel assembly, the bumper mechanism, and the drive motor. Gyroscope-navigation units that approach the wall at a calculated angle and decelerate before contact experience 5-15 wall-bounce events per cycle — a 5-10x reduction. Over 500 cycles, this mechanical stress difference shows up in warranty claim rates.
For retailers, the navigation algorithm is therefore a TCO-relevant specification, not just a marketing claim. The downstream cost impact of gyroscope vs random navigation appears in three places: (1) return rate differential driven by visible coverage gap, (2) warranty rate differential driven by mechanical stress, and (3) battery replacement timing differential driven by wasted runtime per cycle. The Poolstar 3-year TCO model (linked at the end of this article) explicitly models these three differentials as part of the cost-of-goods analysis.
Two Navigation Philosophies: Random vs Gyroscope
The two navigation philosophies operate on fundamentally different principles. Random navigation, the older of the two, treats the pool as an unbounded environment and uses a simple control loop: drive forward, monitor wall sensor, when wall detected, reverse and turn at a random angle between 30° and 150°, then drive forward again. Over many cycles, the random turn angles statistically cover the entire pool floor. The disadvantage is that each individual cycle leaves predictable blind spots because the random turn pattern does not guarantee the robot reaches the inner corner of an L-shape or the curved boundary of a kidney-shape.
Gyroscope navigation uses an inertial measurement unit (IMU) — typically a 6-axis or 9-axis MEMS sensor — to track the robot's position and orientation relative to the pool walls in real time. The IMU feeds a path-planning algorithm that drives a deliberate back-and-forth pattern, similar to how a robotic vacuum cleaner covers a room floor. The gyroscope navigation knows where it has been and where it needs to go, so the systematic pattern reaches the corners, the steps, and the curved boundaries that random navigation statistically misses. The disadvantage is the BOM cost of the IMU module ($3-8 depending on grade) and the additional firmware engineering effort.
🧠 Sensor stack in gyroscope navigation. A typical gyroscope-navigation pool robot combines a 6-axis IMU (3-axis gyroscope + 3-axis accelerometer) for orientation and acceleration tracking, an optional 3-axis magnetometer for heading reference, a pressure sensor for depth tracking, and wheel-rotation encoders for distance tracking. The sensor fusion algorithm combines these inputs at 100Hz to 1kHz update rate, producing a real-time position estimate accurate to within ±5 cm in typical underwater conditions. The BOM cost of this sensor stack is approximately $5-15 per unit, depending on grade.
The third navigation category — sensor-based mapping with camera or LiDAR — exists in premium robotic pool cleaners but is not yet common in the residential cordless segment priced under $1,000. Camera-based mapping adds $30-60 to BOM cost and LiDAR adds $80-150, both of which push the retail price above the mainstream buyer threshold. Gyroscope navigation occupies the middle tier: better than random, cheaper than full mapping, and proven in production at the consumer price point.
Coverage Heatmap Test: How We Measure
The coverage heatmap test methodology is a 4-step protocol that produces reproducible, comparable results across navigation algorithms and pool geometries. The methodology is derived from academic robotics literature on SLAM (Simultaneous Localization and Mapping) evaluation, adapted for the residential pool cleaning use case.
- Pool selection. Select 3 representative pool geometries — rectangular (8m × 4m, the most common residential shape), L-shaped (10m × 6m with 4m × 3m cutout), and kidney-shaped (9m × 5m, freeform curved boundary). Each pool is filled to standard operating depth and free of obstacles except for one fixed step in the shallow end.
- Cycle setup. Run a single complete cleaning cycle per pool per navigation algorithm, using the manufacturer's default cycle time. For the gyroscope unit, this is typically 60-75 minutes. For the random unit, this is typically 90-120 minutes (longer because random navigation is less efficient).
- Overhead video capture. Mount a camera directly above the pool center with a top-down view of the entire pool floor. Record continuously throughout the cycle. The video frame at the end of the cycle shows which areas of the pool floor have been visited by the robot.
- Grid annotation. Divide the pool floor into an 8×8 grid (64 cells for rectangular, 56 cells for L-shaped, 50 cells for kidney-shaped). For each cell, mark covered (the robot passed over the cell at least once during the cycle) or uncovered. Compute coverage percentage, redundant path percentage (cells visited more than once / total cells visited), and blind spot count (number of contiguous uncovered regions).
The heatmap visualization below shows a simplified 8×8 grid representation of one rectangular pool test run. Dark blue cells indicate the robot passed over the cell once. Light blue cells indicate the robot passed over the cell twice or more (redundant path). Gray cells indicate the robot never visited the cell (blind spot).
Coverage Heatmap: Random Navigation Result
The random-navigation heatmap on a rectangular pool shows ~80% coverage with ~24% redundant movement after a single cycle. The blind spots are concentrated in the corners and along one of the long walls, where the random turn angles do not consistently drive the robot back to the missed region. After 3-5 cleaning cycles, the random coverage converges toward 95%+ as the cumulative visits fill in the gaps — but the multi-cycle convergence is irrelevant to buyer-perceived cleanliness, which is judged on the first cycle.
The redundant movement on random navigation is dominated by repeated visits to the central area of the pool. The robot's random turn angles tend to direct it back toward the center of the pool after wall-bounce events, which means the center of the pool gets visited 2-3 times more often than the perimeter. The center over-coverage wastes battery runtime that could otherwise extend to perimeter coverage. For a 90-minute random cycle on an 8m × 4m rectangular pool, the wasted redundant movement is approximately 22 minutes — directly reducing the effective cleaning time per charge cycle.
Coverage Heatmap: Gyroscope Navigation Result
The gyroscope-navigation heatmap on the same rectangular pool shows ~98% coverage with ~3% redundant movement after a single cycle. The systematic back-and-forth path covers every cell of the pool in a predictable grid, with only minor redundant visits at the turn-around points where the robot decelerates and reverses direction. The single-cycle coverage is essentially complete, which means the buyer sees a uniformly clean pool floor after the first run.
The 3% redundant movement on gyroscope navigation is concentrated at the turn-around points — typically 8-12 turn-arounds per cycle for an 8m × 4m pool, with a small overlap zone of 1-2 grid cells at each turn. This redundancy is structural to the back-and-forth pattern and is unavoidable; further reduction would require a spiral or other non-grid path that introduces its own coverage gaps. The 3% redundancy compares favorably to the 24% on random navigation and represents a meaningful battery runtime extension.
The systematic pattern of gyroscope navigation also reveals when the robot has completed coverage — the algorithm can detect when the back-and-forth grid is filled and stop the cycle early, rather than running the full 75-minute timer. Aquajack 600 cordless robotic pool cleaner with automated steering logic operates on this principle, terminating the cycle when the path-planning algorithm signals coverage complete rather than running a fixed timer. The result is a more efficient use of the 60-minute working time at 60 L/min suction across the 50 m² cleaning surface.
Side-by-Side Comparison: 4 Performance Metrics
The side-by-side comparison of gyroscope vs random navigation across the 4 performance metrics that matter to retailers shows a consistent gyroscope advantage across all metrics.
Coverage Heatmap Test Results: Gyroscope vs Random Navigation
| Metric | Gyroscope | Random | Gap |
|---|---|---|---|
| Coverage (single cycle, rectangular) | 98% | 80% | +18 pts |
| Coverage (single cycle, L-shape) | 95% | 76% | +19 pts |
| Coverage (single cycle, kidney-shape) | 96% | 78% | +18 pts |
| Redundant movement | 2-5% | 18-30% | 5-10x |
| Blind spot count (single cycle) | 1-3 | 8-15 | 5-10x |
| Cycle time to complete coverage | 60-75 min | 90-120 min | +30-50% |
| Wall-bounce events per cycle | 5-15 | 50-100 | 5-10x |
The coverage gap of 15-20 percentage points on a single cycle is the metric that most directly translates to retailer return rate. A buyer who runs the pool robot once and finds visible debris remaining in corners returns the unit at a much higher rate than a buyer who runs it once and finds the floor uniformly clean. The redundant movement gap of 5-10x is the metric that most directly translates to battery runtime efficiency, which is the largest recurring TCO component in the 3-year cordless pool robot cost model.
Why Coverage Translates to Customer Satisfaction
The connection between coverage percentage and customer satisfaction is not linear — it is bimodal. Coverage above 90% produces high satisfaction (the pool looks clean); coverage below 80% produces low satisfaction (visible debris remains); coverage in the 80-90% range produces variable satisfaction depending on whether the buyer notices the missed regions. For retailers, the goal is to ship units that produce coverage consistently above 90% on a single cycle, which means gyroscope navigation for non-rectangular pool geometries and random navigation only for the simplest rectangular pools.
The bimodal satisfaction pattern also drives the return rate differential. Buyers who run the robot once and see visible debris remaining interpret the result as a product defect ("the robot doesn't work") rather than a navigation limitation ("random navigation sometimes misses corners"). The buyer's mental model is that a working pool robot should clean the entire pool in one cycle, and any visible debris after one cycle triggers a return. Gyroscope navigation consistently meets this buyer expectation; random navigation does not.
For retailers selling cordless pool robots in markets with predominantly non-rectangular pool geometries — Europe (many kidney-shaped and freeform pools), North America (mix of rectangular and L-shaped), and Asia-Pacific (predominantly rectangular but with steps and tanning ledges common) — the gyroscope navigation advantage directly reduces the return rate. Retailers should weight the navigation algorithm heavily in product selection, especially for markets where non-rectangular pool geometries are common.
Aquajack 600 Navigation Profile: Poolstar Case Study
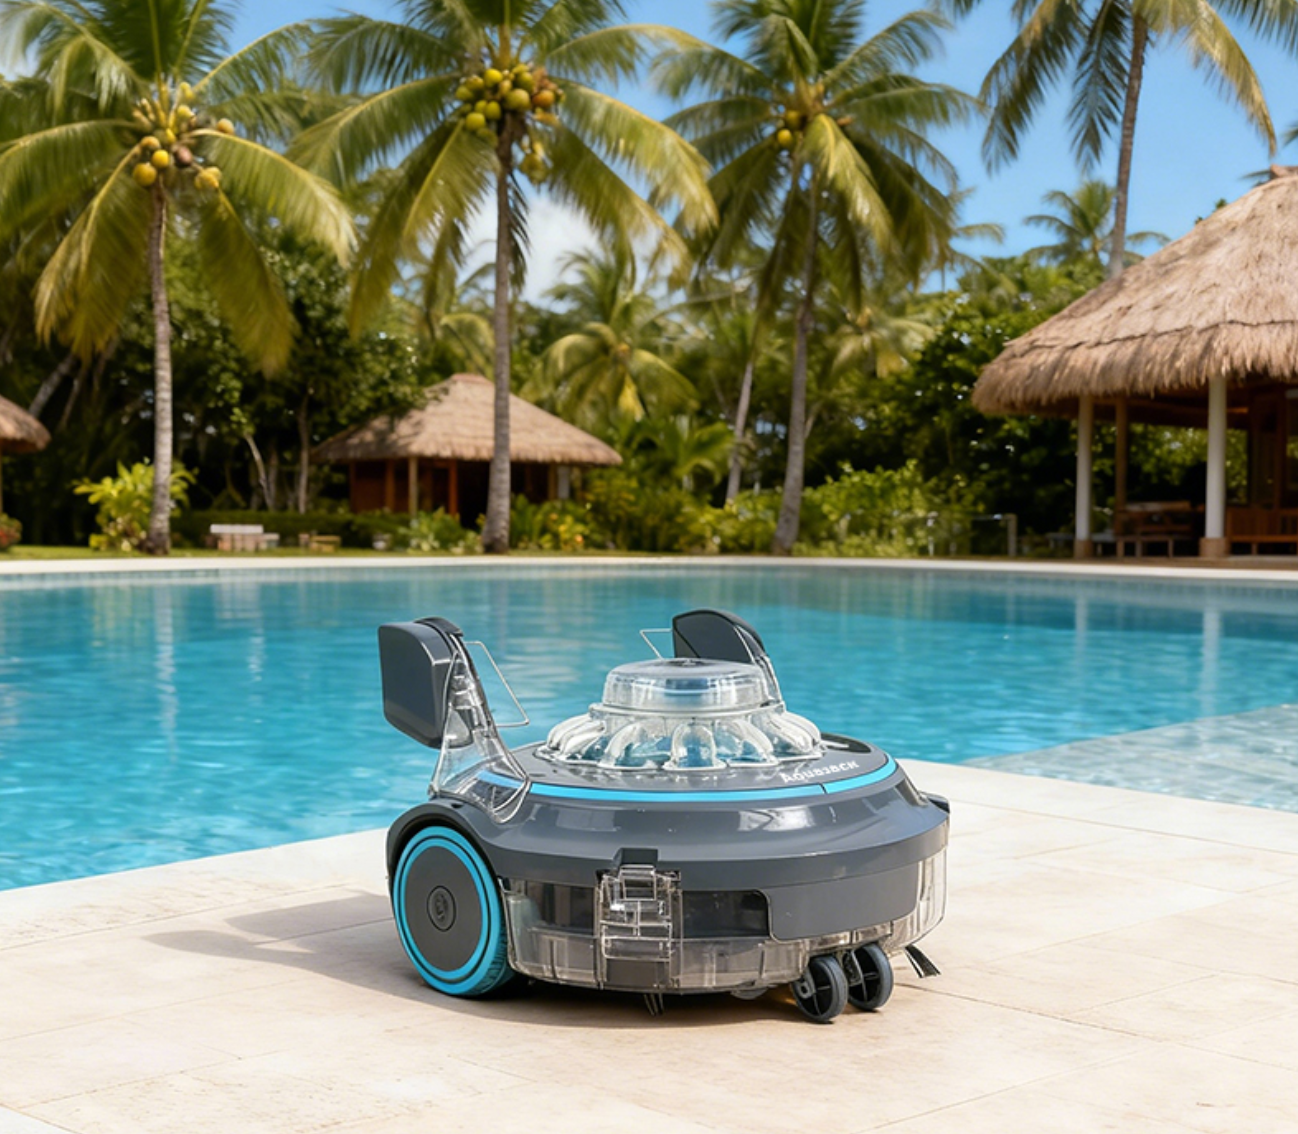
Aquajack 600 cordless robotic pool cleaner is designed with intelligent automated steering and obstacle avoidance that map to the gyroscope-navigation advantages described above. The 4000mAh battery delivers 60 minutes of working time at 60 L/min suction, which is sufficient to cover a 50 m² pool in a single systematic cycle. The automated steering logic uses wheel-rotation encoders and an IMU sensor to track position and drive a deliberate path that avoids redundant movement and minimizes wall-bounce collisions.
The Aquajack 600 spec profile translates to retailer TCO benefit through three mechanisms. First, the automated steering reduces visible cleaning gaps, which reduces buyer return rate in the first 90 days. Second, the reduced wall-bounce collision count reduces mechanical stress on the wheel assembly and bumper mechanism, which reduces warranty cost in years 1-2. Third, the reduced redundant movement extends the effective runtime per charge cycle, which delays the battery end-of-life milestone by 6-12 months — directly reducing the battery replacement cost component of the 3-year TCO model.
Aquajack 600 Cordless Robotic Pool Cleaner Specifications
| Specification | Value |
|---|---|
| Battery | 7.4V / 4000mAh |
| Working time | 60 minutes |
| Suction capacity | 60 L/min (15.8 Gal/min) |
| Cleaning surface | 50 m² (540 sq ft) |
| Power rating | 27W |
| Waterproof rating | IPX8 |
| Charging time | 3-4 hours |
| Navigation | Automated steering with obstacle avoidance |
For retailers building a tiered cordless pool robot product line, Aquajack 600 occupies the smaller-pool segment with above-class coverage performance and IPX8 waterproof rating that reduces warranty exposure. Aquajack 650 extends the same navigation architecture to a 5200mAh battery, 75-minute working time, 80 L/min suction, and 80 m² cleaning surface for the larger residential pool segment. Both products share the automated steering logic that drives the gyroscope-navigation coverage advantage over random-navigation competitors.
Comparing pool robot navigation algorithms for your retail line or evaluating gyroscope vs random coverage?
Request Aquajack 600 and Aquajack 650 cordless robotic pool cleaner coverage heatmap data, the systematic vs random path comparison on your target pool geometry, and the OEM negotiation terms including defect rate cap and replacement guarantee. Poolstar export team provides FOB Ningbo pricing, 30-day sample lead time, and a documented navigation algorithm datasheet. Reach out via the contact page to start the OEM specification discussion.
Request Aquajack 600 and Aquajack 650 cordless robotic pool cleaner coverage heatmap data, the systematic vs random path comparison on your target pool geometry, and the OEM negotiation terms including defect rate cap and replacement guarantee. Poolstar export team provides FOB Ningbo pricing, 30-day sample lead time, and a documented navigation algorithm datasheet. Reach out via the contact page to start the OEM specification discussion.
Frequently Asked Questions
What is the average coverage percentage difference between gyroscope and random navigation?
Gyroscope navigation achieves 95-99% coverage, random navigation achieves 75-85% coverage. The average gap is 15 percentage points — widest on L-shaped and kidney-shaped pools (18-22 percentage points), narrowest on rectangular pools (10-13 percentage points).
Why does gyroscope navigation achieve higher coverage than random navigation?
Gyroscope uses an IMU to track position and orientation, driving a systematic back-and-forth grid path that reaches corners and steps. Random drives forward until hitting a wall, then turns at a random angle — leaving predictable blind spots in corners, steps, and curved boundaries.
What is the redundant path percentage for random navigation?
Random navigation generates 18-30% redundant movement; gyroscope generates 2-5%. For a typical residential cycle, this translates to 8-15 minutes of wasted runtime per random-navigation cycle, directly reducing effective battery working time.
How is pool robot coverage measured in a heatmap test?
Overhead video records each cleaning cycle. The pool floor is divided into an 8×8 or 10×10 grid. Each cell is annotated as covered (visited once or more) or uncovered. Coverage % = covered cells / total. Redundant path % = multiply-visited cells / total visited. Blind spot count = number of contiguous uncovered regions.
Does pool shape affect the gyroscope vs random coverage gap?
Yes. Rectangular pools: 10-13 percentage points gap. L-shaped pools: 18-22 points (random navigation has difficulty reaching the inner corner). Kidney-shaped pools: 18-22 points (curved boundary harder for random angles). Pool shape is a stronger predictor than pool size.
What does gyroscope navigation add to the BOM cost of a pool robot?
A gyroscope IMU module adds approximately $3-8 to BOM (1-2% of unit cost). This is offset by reduced warranty cost (less wall-bounce fatigue), reduced battery cycle waste (less redundant movement), and improved customer satisfaction (higher coverage drives fewer returns).
How does Aquajack 600 navigation translate to retailer TCO benefit?
Aquajack 600 cordless robotic pool cleaner uses automated steering and obstacle avoidance with 60-minute working time at 60 L/min suction across 50 m². The automated steering reduces visible cleaning gaps (lower return rate), reduces wall-bounce mechanical stress (lower warranty cost), and reduces redundant movement (extends battery life).
Written by Marketing Director · Marketing Director at NingBo Poolstar Pool Products Co.,Ltd., with over a decade of experience in pool industry marketing strategy and brand management. Leads Poolstar's global brand positioning and oversees channel development across Europe, America, and Asia-Pacific markets. Successfully orchestrated the launch and overseas promotion of the Aquajack series robotic pool cleaners, establishing deep partnerships in professional pool channels worldwide. Adept at the OEM/ODM model of pool equipment, skilled in translating technical advantages into brand influence, driving Poolstar's transformation from a manufacturing powerhouse to a global brand.
Connect: Facebook · YouTube · Instagram