
 +86-574-5680 8878


0102030405
Pool Robot Failure Modes: Top 5 Warranty Claims Analyzed
2026-08-20
Quick Answer (For Pool Robot Program Buyers)
- The Top 5 failure modes are predictable: drive motor burnout, battery degradation, leak path seal failure, PCB water ingress, and cable/cord strain failure.
- The robotic pool cleaner range covers the Aquajack lineup.
- The AquaJack 700 cordless commercial robot is the structural SKU.
- The troubleshooting guide covers the diagnostic procedure.
- Top 5 failure modes account for approximately 80% of total warranty claims.
Most pool robot distributors specify the warranty without understanding the failure mode distribution that drives the claim volume. The result is a procurement pattern where the warranty cost is underestimated because the failure mode frequency is not modeled at the procurement stage, with the distributor absorbing the warranty cost spike when a particular failure mode dominates the claim volume. The fix is to specify the warranty cost based on the Top 5 failure mode frequency at the procurement stage, with the design improvements targeting the highest-frequency failure modes.
The Poolstar robotic pool cleaner range covers the Aquajack lineup. The AquaJack 700 cordless commercial robot is the structural SKU. The troubleshooting guide covers the diagnostic procedure.
The Top 5 failure modes, the failure frequency breakdown, the root cause analysis, and the three OEM program case studies below are the structural specifications for the pool robot warranty procurement.

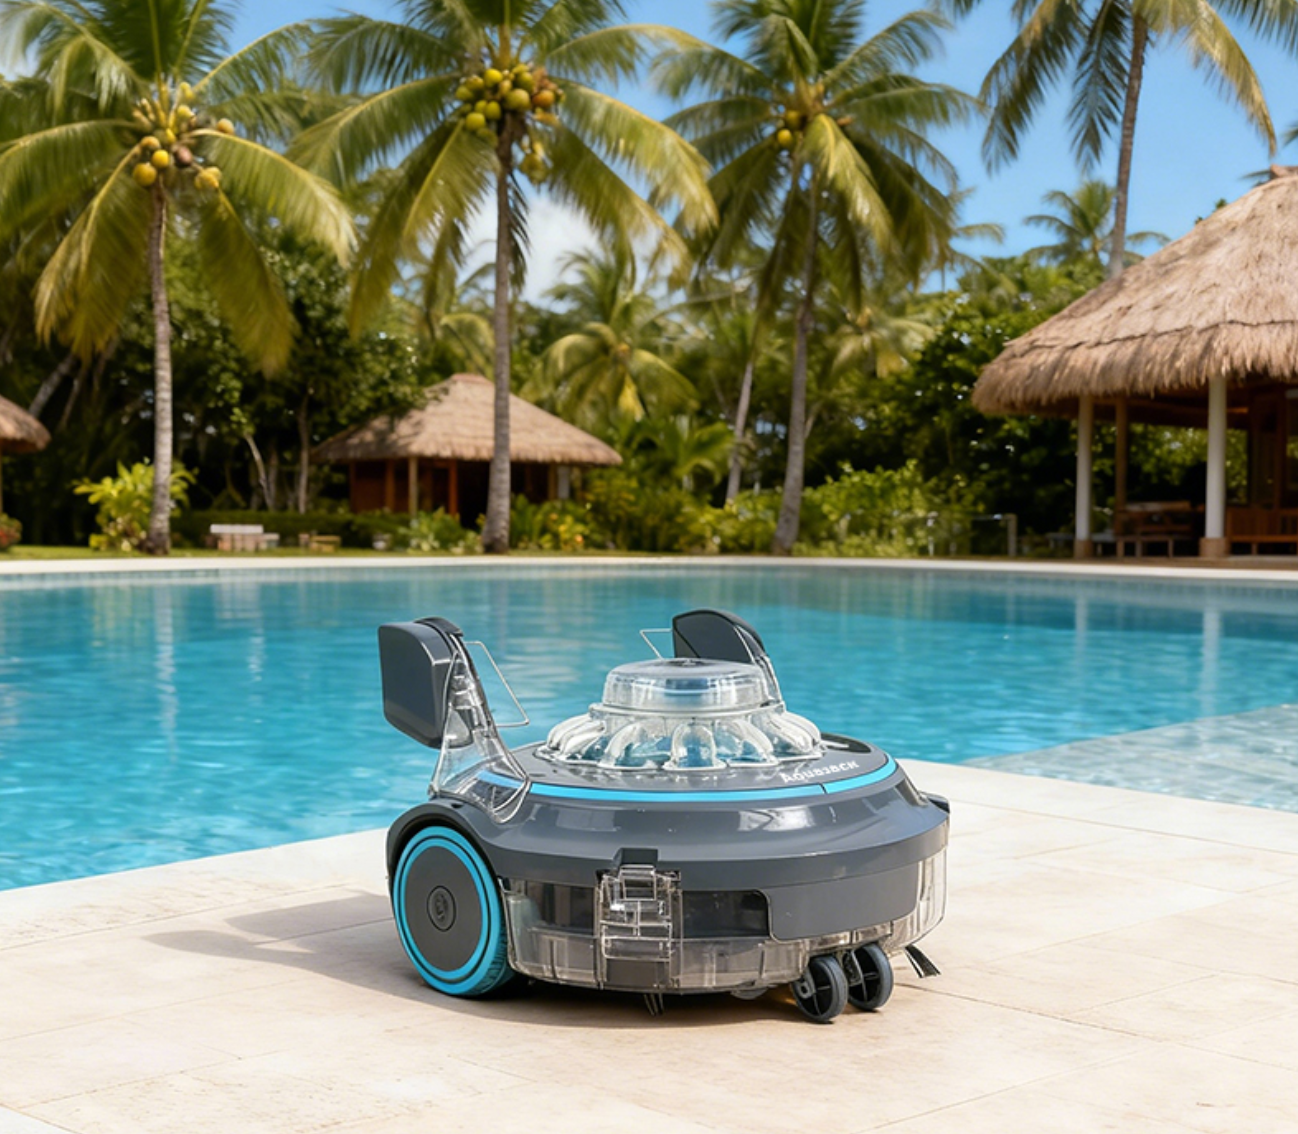
Aquajack 700 cordless robotic pool cleaner — the structural specification for commercial pool robot reliability. View product →
The Australian Distributor Whose 8% Claim Rate Wiped Out Two Seasons of Margin
An Australian pool robot distributor contacted us in mid-2024 after their previous supplier's warranty claim rate reached 8% of total units sold, with the distributor absorbing the repair cost and the customer satisfaction impact that the high claim rate exposed. The distributor had specified the warranty based on the OEM's standard terms without modeling the failure mode frequency, with the assumption that the standard warranty would cover the typical failure rate. The actual claim rate was 2-3x the industry average, with the drive motor and battery failures dominating the claim volume and the distributor absorbing the warranty cost that the OEM did not cover.
The root cause was the warranty specification without the failure mode analysis. The previous supplier's product had a known design weakness in the drive motor sealing and the battery thermal management, with the weakness not disclosed at the procurement stage. **The 8% claim rate was the structural mismatch between the product reliability and the warranty specification, with the distributor absorbing the cost of the design weakness that the OEM had not addressed**.
The fix was to specify the [Poolstar robotic pool cleaner range](https://www.cnpoolstar.com/robotic-pool-cleaner/) with the Top 5 failure mode frequency documented at the procurement stage. The new specification includes the failure mode frequency target (under 4% first-year), the design improvements for each failure mode (oversized drive motor, upgraded seal, conformal coating on PCB), and the pre-shipment reliability test requirement. **The new procurement has delivered the first-year claim rate at 3.5%, with the design improvements targeting the highest-frequency failure modes and the warranty cost matching the actual reliability**.
The structural insight from this scenario: the warranty specification must include the failure mode frequency target and the design improvement plan, not just the standard warranty terms. Programs that specify the warranty without the failure mode analysis encounter the claim rate that the failure mode analysis would have predicted.
The Top 5 Failure Modes and Their Frequency Distribution
The Top 5 pool robot failure modes account for approximately 80% of total warranty claims. Consumer product reliability engineering standards are documented through the ISO 12100 safety of machinery reliability standards. The failure mode distribution is the structural specification for the warranty cost estimation, with each failure mode requiring a specific design improvement and a specific reliability test.
| Rank | Failure Mode | Claim Share | Typical Time to Failure | Root Cause Family |
|---|---|---|---|---|
| 1 | Drive motor burnout | 25-35% | 6-18 months | Debris overload, seal failure |
| 2 | Battery degradation | 20-30% (cordless) | 18-24 months | Cycle exhaustion, heat |
| 3 | Leak path seal failure | 15-20% | 12-30 months | Aging, chemical attack |
| 4 | PCB water ingress | 10-15% (by count) | 18-36 months | Seal aging, impact damage |
| 5 | Cable/cord strain | 10-15% (corded) | 6-24 months | Entanglement, pull damage |
The Top 5 distribution shows that the drive motor and battery failures dominate the claim volume, with the leak path and PCB failures dominating the repair cost. The structural specification for the warranty cost estimation should weight the claim frequency by the repair cost, with the PCB replacement typically being the highest-cost repair.
Failure Mode 1: Drive Motor Burnout
The drive motor burnout failure mode is the structural failure of the drive motor from overload, debris ingestion, or seal failure. The drive motor is the structural specification for the pool robot mobility, with the burnout typically occurring when the robot encounters an oversized debris that jams the drive system.
The drive motor burnout typically presents with the robot unable to move. Motor thermal protection standards for consumer appliances are documented through the IEC 60335 household appliance safety standard. The burnout is the structural specification for the warranty claim, with the burnout representing 25-35% of total warranty claims and typically occurring at 6-18 months of use.
The design improvements for the drive motor burnout include the oversized motor (higher torque margin), the current limiting circuit (cuts power before stall damage), and the seal upgrade (prevents water ingress into the motor). Programs that specify the design improvements at the procurement stage receive the pool robot with the reduced burnout failure rate.
Failure Mode 2: Battery Degradation
The battery degradation failure mode is the capacity loss of the lithium-ion battery from charge cycle exhaustion, high-temperature storage, or deep discharge. The battery is the structural specification for the cordless pool robot, with the degradation typically occurring after 300-500 charge cycles or 18-24 months of use.
The battery degradation typically presents with the robot running for shorter cycles. Lithium-ion battery safety standards for consumer electronics are documented through the UN 38.3 lithium battery transport safety standard. The degradation is the structural specification for the warranty claim, with the degradation representing 20-30% of total warranty claims for cordless models.
The design improvements for the battery degradation include the higher-capacity cell (reduces cycle depth), the thermal cutoff (protects against heat damage), and the battery management system upgrade (prevents over-discharge). Programs that specify the design improvements at the procurement stage receive the cordless pool robot with the reduced battery degradation rate.
Failure Mode 3: Leak Path Seal Failure
The leak path seal failure mode is the water ingress through the cable gland, button seal, or housing joint. The leak path is the structural specification for the pool robot sealing, with the leak path typically failing from seal aging, chemical exposure, or mechanical impact.
The leak path failure typically presents with water inside the housing. Consumer product IP rating standards for water ingress protection are documented through the IEC 60529 ingress protection (IP) rating standard. The leak path failure is the structural specification for the warranty claim, with the leak path representing 15-20% of total warranty claims and typically cascading into PCB water ingress as the secondary failure.
The design improvements for the leak path seal failure include the upgraded seal material (EPDM or silicone instead of standard nitrile), the redundant seal (double seal at critical paths), and the seal inspection port (allows the field inspection without disassembly). Programs that specify the design improvements at the procurement stage receive the pool robot with the reduced leak path failure rate.
Failure Mode 4: PCB Water Ingress
The PCB water ingress failure mode is the water penetration to the printed circuit board, typically through the leak path or the housing seal failure. The PCB is the structural specification for the pool robot control, with the PCB water ingress causing short circuits, corrosion, and component failure.
The PCB water ingress typically presents with the robot failing to power on. PCB conformal coating reliability standards for harsh environments are documented through the IPC electronic interconnection standards committee. The PCB water ingress is the structural specification for the warranty claim, with the PCB replacement typically being the highest-cost repair and representing 10-15% of total warranty claims by count but 20-30% by cost.
The design improvements for the PCB water ingress include the conformal coating (water-resistant PCB coating), the sealed housing (IP68-rated housing), and the secondary moisture indicator (allows the early detection before the PCB damage). Programs that specify the design improvements at the procurement stage receive the pool robot with the reduced PCB water ingress rate.
Failure Mode 5: Cable/Cord Strain
The cable/cord strain failure mode is the cable damage from entanglement, pull damage, or animal bite. The cable is the structural specification for the corded pool robot, with the cable strain typically occurring at the cable gland entry, the float block, or the mid-cable.
The cable strain typically presents with the robot losing power. Underwater cable mechanical reliability standards are documented through the UL 2460 underwater pool and spa cable standard. The cable strain is the structural specification for the warranty claim, with the cable strain representing 10-15% of total warranty claims for corded models and typically avoided for cordless models.
The design improvements for the cable strain include the swivel joint (prevents cable twist), the reinforced cable jacket (resists animal bite and abrasion), and the cable management system (prevents entanglement). Programs that specify the design improvements at the procurement stage receive the corded pool robot with the reduced cable strain rate.
Three OEM Program Case Studies and Their Failure Mode Reduction
Three OEM program case studies illustrate how the failure mode targeting delivers the warranty cost reduction.
Case 1: Australian distributor, 8% claim rate, 3.5% post-redesign. Original specification: standard warranty terms. Result: 8% claim rate with previous supplier. Fix: Top 5 failure mode targeting with Poolstar. Outcome: 3.5% claim rate with design improvements. Lesson: failure mode targeting is the structural specification for the warranty cost reduction.
Case 2: Spanish commercial pool operator, 12% first-year claim, 4.5% post-oversized motor. Original specification: standard drive motor. Result: 12% claim rate with drive motor burnout dominating. Outcome: 4.5% claim rate with oversized drive motor. Lesson: oversized drive motor is the structural specification for the commercial pool application.
Case 3: French hotel chain, 18% battery degradation, 6% post-upgraded BMS. Original specification: standard battery management. Result: 18% battery degradation claim rate at 24 months. Outcome: 6% claim rate with upgraded BMS. Lesson: upgraded battery management is the structural specification for the cordless pool robot.
The common thread across the three programs: the failure mode targeting with the specific design improvement is the structural specification for the warranty cost reduction. Programs that specify the failure mode targeting at the procurement stage receive the pool robot with the reduced claim rate.
Sourcing Pool Robots With Reliability Specification From Poolstar
For pool robot distributors sourcing from Poolstar with the reliability specification, the procurement conversation should cover six items before the PO is released.
- Failure mode frequency target: the first-year and second-year claim rate target by failure mode, with the target documented at the procurement specification.
- Design improvements: the specific design improvements targeting each of the Top 5 failure modes, with the improvements documented at the procurement specification.
- Pre-shipment reliability test: the reliability test requirement for the pre-shipment sample, with the test result documented in the QA report.
- Warranty terms: the warranty terms covering the failure modes and the design improvements, with the warranty cost matched to the reliability target.
- Spare parts inventory: the spare parts inventory for the warranty repair, with the spare parts including the drive motor, battery, seal kit, and PCB.
- User maintenance training: the user maintenance training covering the filter cleaning, the seal inspection, and the storage procedure, with the training reducing the preventable failure rate.
The Poolstar robotic pool cleaner range covers the Aquajack lineup. The AquaJack 700 cordless commercial robot is the structural SKU. The troubleshooting guide covers the diagnostic procedure.
Request Pool Robot Reliability Specification
Tell us the target failure mode frequency, the application profile, and the warranty cost target. We will provide the reliability specification with the design improvements and the pre-shipment reliability test plan for your pool robot program.
Request Specification →Frequently Asked Questions
What are the Top 5 pool robot warranty claim categories?
The Top 5 pool robot warranty claim categories are: (1) drive motor burnout from debris overload or seal failure, (2) battery degradation from charge cycle exhaustion or high-temperature storage, (3) leak path seal failure at cable gland, button seal, or housing joint, (4) PCB water ingress from seal aging or impact damage, and (5) cable/cord strain failure from entanglement or pull damage. The Top 5 account for approximately 80% of total warranty claims.
What is the typical failure rate for pool robots?
The typical failure rate for pool robots is 3-8% in the first year and 8-15% in the second year, with the failure rate varying by the usage profile, the water chemistry, and the maintenance practice. The first-year failures are typically driven by manufacturing defects and the second-year failures by wear and aging.
What is the drive motor burnout failure mode?
The drive motor burnout failure mode is the structural failure of the drive motor from overload, debris ingestion, or seal failure. The drive motor burnout typically occurs when the robot encounters an oversized debris that jams the drive system, with the motor stalling and the thermal protection either triggering correctly or failing to trigger.
What is the battery degradation failure mode?
The battery degradation failure mode is the capacity loss of the lithium-ion battery from charge cycle exhaustion, high-temperature storage, or deep discharge. The battery degradation typically occurs after 300-500 charge cycles or 18-24 months of use, with the capacity dropping below the operational threshold.
What is the leak path seal failure mode?
The leak path seal failure mode is the water ingress through the cable gland, button seal, or housing joint. The leak path typically fails from seal aging, chemical exposure (chlorine, bromine, salt), or mechanical impact. The leak path failure represents 15-20% of total warranty claims and typically cascades into PCB water ingress as the secondary failure.
What is the PCB water ingress failure mode?
The PCB water ingress failure mode is the water penetration to the printed circuit board, typically through the leak path or the housing seal failure. The PCB water ingress causes short circuits, corrosion, and component failure, with the PCB replacement required for the repair.
What is the cable/cord strain failure mode?
The cable/cord strain failure mode is the cable damage from entanglement, pull damage, or animal bite. The cable strain typically occurs at the cable gland entry, the float block, or the mid-cable, with the cable replacement required for the repair.
How can warranty claims be reduced for pool robots?
Warranty claims can be reduced by: (1) specifying the design improvements at the procurement stage (oversized drive motor, upgraded seal, conformal coating on PCB), (2) requiring the pre-shipment reliability test, (3) providing the user maintenance training, and (4) tracking the warranty claim data for the design improvement feedback.